---
title: "DepthImage"
---
A depth image, i.e. as captured by a depth camera.
Each pixel corresponds to a depth value in units specified by [`components.DepthMeter`](https://rerun.io/docs/reference/types/components/depth_meter).
## Fields
### Required
* `buffer`: [`ImageBuffer`](https://rerun.io/docs/reference/types/components/image_buffer.md)
* `format`: [`ImageFormat`](https://rerun.io/docs/reference/types/components/image_format.md)
### Optional
* `meter`: [`DepthMeter`](https://rerun.io/docs/reference/types/components/depth_meter.md)
* `colormap`: [`Colormap`](https://rerun.io/docs/reference/types/components/colormap.md)
* `depth_range`: [`ValueRange`](https://rerun.io/docs/reference/types/components/value_range.md)
* `point_fill_ratio`: [`FillRatio`](https://rerun.io/docs/reference/types/components/fill_ratio.md)
* `draw_order`: [`DrawOrder`](https://rerun.io/docs/reference/types/components/draw_order.md)
* `magnification_filter`: [`MagnificationFilter`](https://rerun.io/docs/reference/types/components/magnification_filter.md)
## Can be shown in
* [Spatial2DView](https://rerun.io/docs/reference/types/views/spatial2d_view.md)
* [Spatial3DView](https://rerun.io/docs/reference/types/views/spatial3d_view.md) (if logged under a projection)
* [DataframeView](https://rerun.io/docs/reference/types/views/dataframe_view.md)
## API reference links
* 🌊 [C++ API docs for `DepthImage`](https://ref.rerun.io/docs/cpp/stable/structrerun_1_1archetypes_1_1DepthImage.html)
* 🐍 [Python API docs for `DepthImage`](https://ref.rerun.io/docs/python/stable/common/archetypes#rerun.archetypes.DepthImage)
* 🦀 [Rust API docs for `DepthImage`](https://docs.rs/rerun/latest/rerun/archetypes/struct.DepthImage.html)
## Examples
### Simple example
```python
"""Create and log a depth image."""
import numpy as np
import rerun as rr
depth_image = 65535 * np.ones((200, 300), dtype=np.uint16)
depth_image[50:150, 50:150] = 20000
depth_image[130:180, 100:280] = 45000
rr.init("rerun_example_depth_image_simple", spawn=True)
# Log the tensor, assigning names to each dimension
rr.log("depth", rr.DepthImage(depth_image, meter=10_000.0))
```
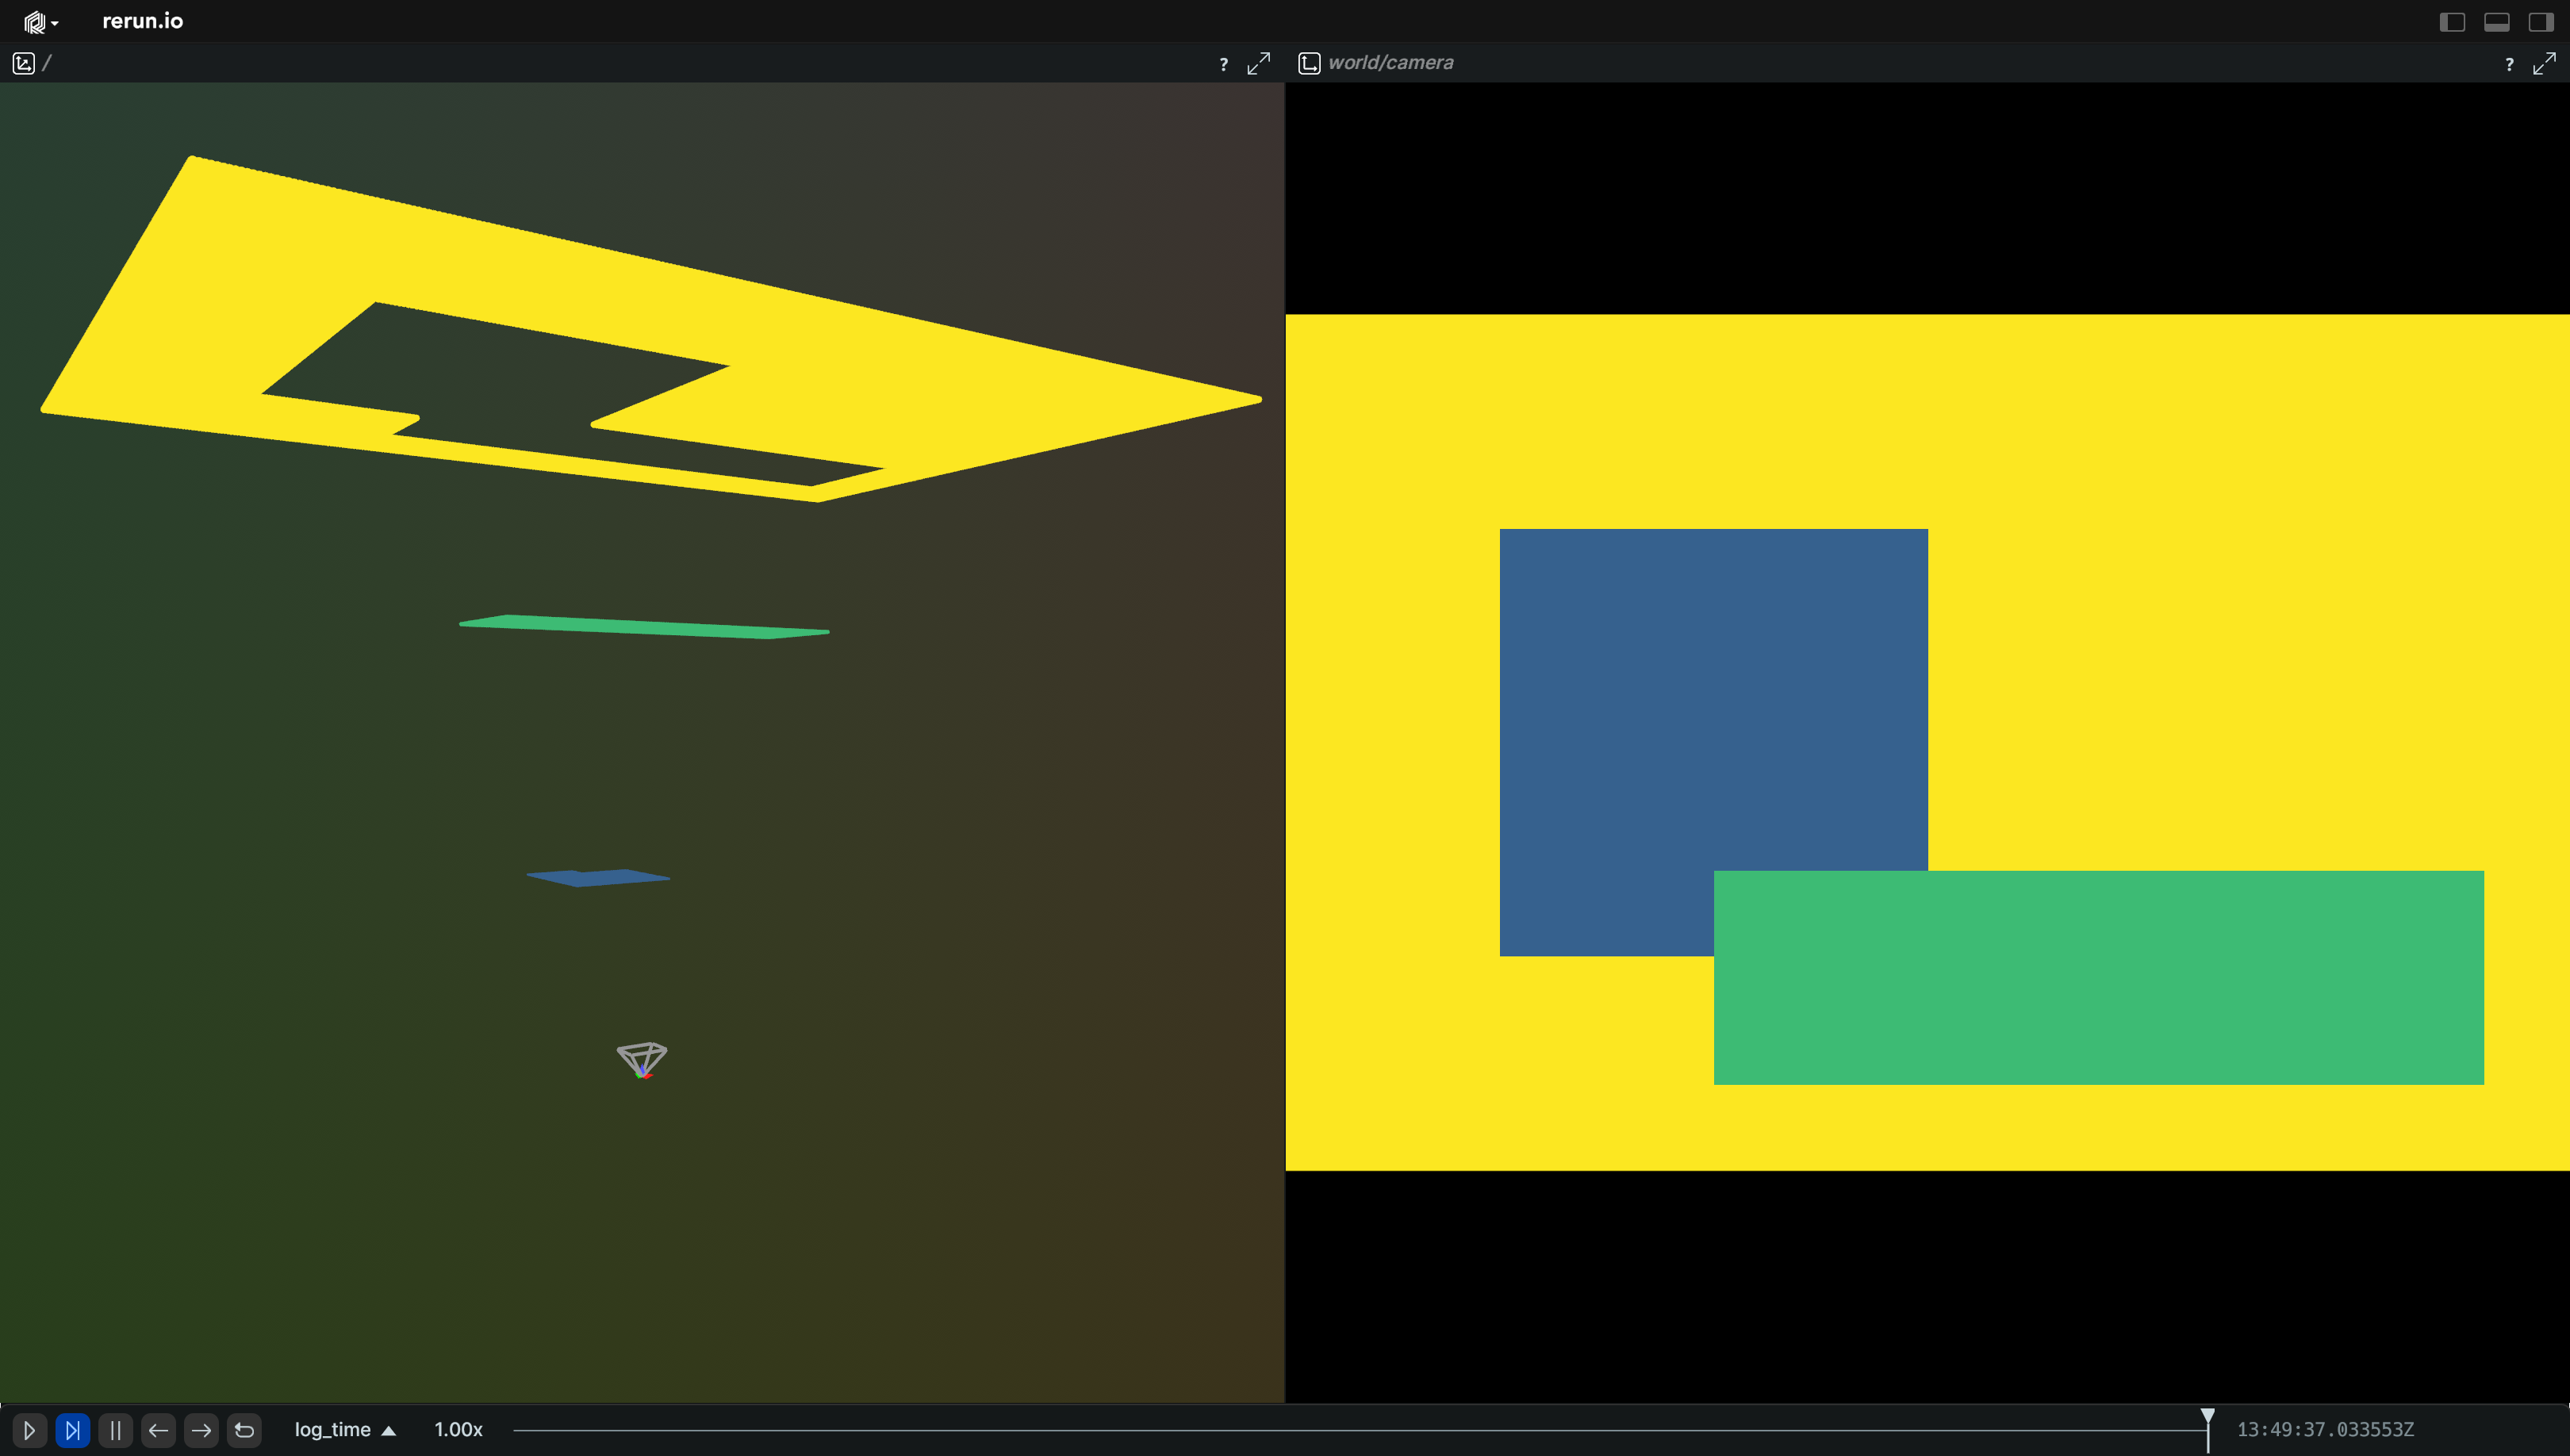
### Depth to 3D example
```python
"""Create and log a depth image and pinhole camera."""
import numpy as np
import rerun as rr
depth_image = 65535 * np.ones((200, 300), dtype=np.uint16)
depth_image[50:150, 50:150] = 20000
depth_image[130:180, 100:280] = 45000
rr.init("rerun_example_depth_image_3d", spawn=True)
# If we log a pinhole camera model, the depth gets automatically
# back-projected to 3D
rr.log(
"world/camera",
rr.Pinhole(
width=depth_image.shape[1],
height=depth_image.shape[0],
focal_length=200,
),
)
# Log the tensor.
rr.log(
"world/camera/depth",
rr.DepthImage(depth_image, meter=10_000.0, colormap="viridis"),
)
```