See what you can build with Rerun
A tour of Rerun in action: live recordings, code, and walkthroughs across robotics, computer vision, and machine learning.
The experiment loop
Collect, prepare, train, evaluate. Then do it again.
Every model improvement is another trip around the loop. Each example covers one or more steps, with Rerun as the place you look at the data in between.
Collect → Prepare
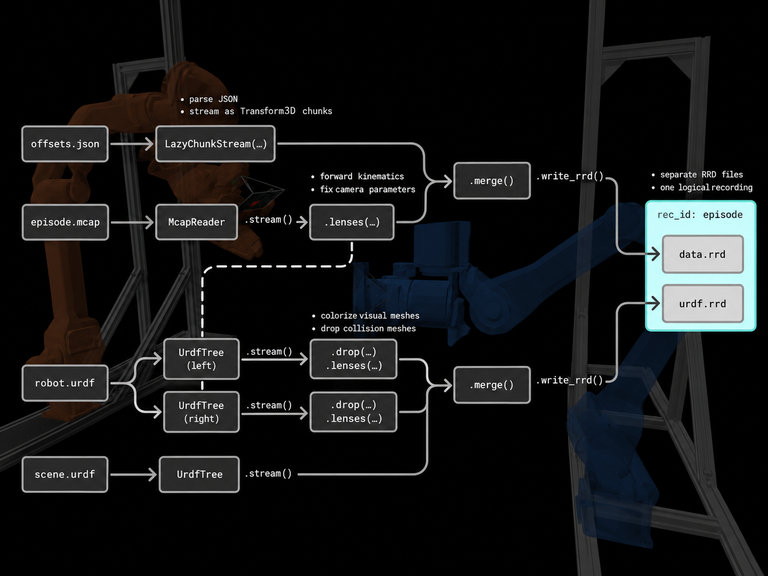
Robot data preprocessing example
Assemble a robot recording from multiple file sources with Rerun's chunk processing API and preprocessing steps.
API example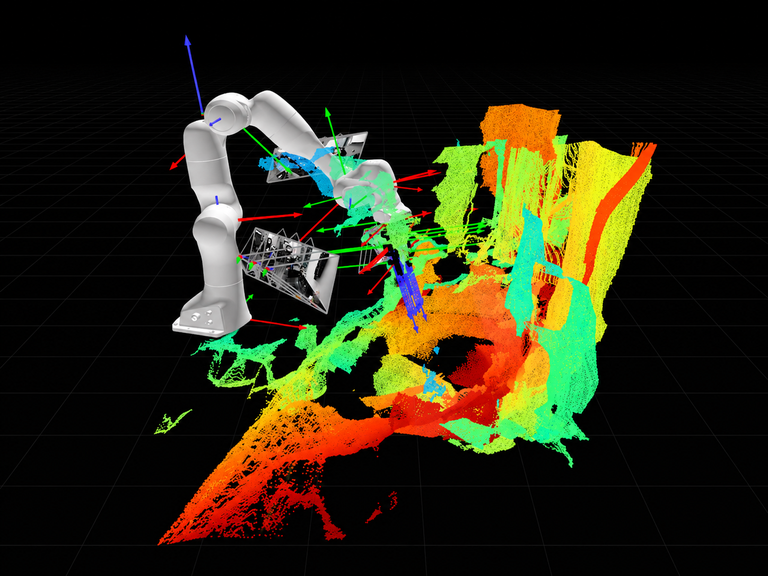
Collect
DROID
Visualize the DROID robot manipulation dataset: joint states, wrist and side-view stereo cameras, and teleoperator actions.
2D 3D Depth Pinhole camera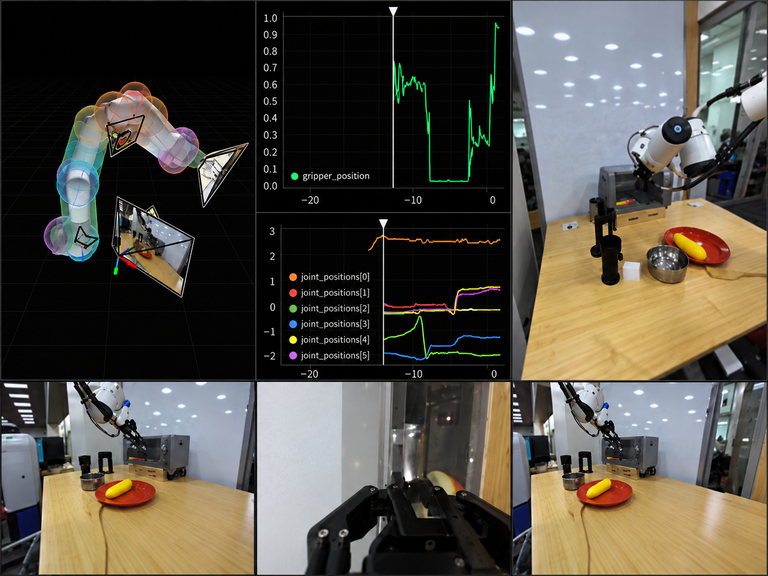
Prepare
DROID semantic frame search
Find moments in robot demonstrations by describing them in plain language. Embeddings flow from a Rerun dataset into a vector store and deep-link back into the viewer.
Robotics Semantic search Embeddings SigLIP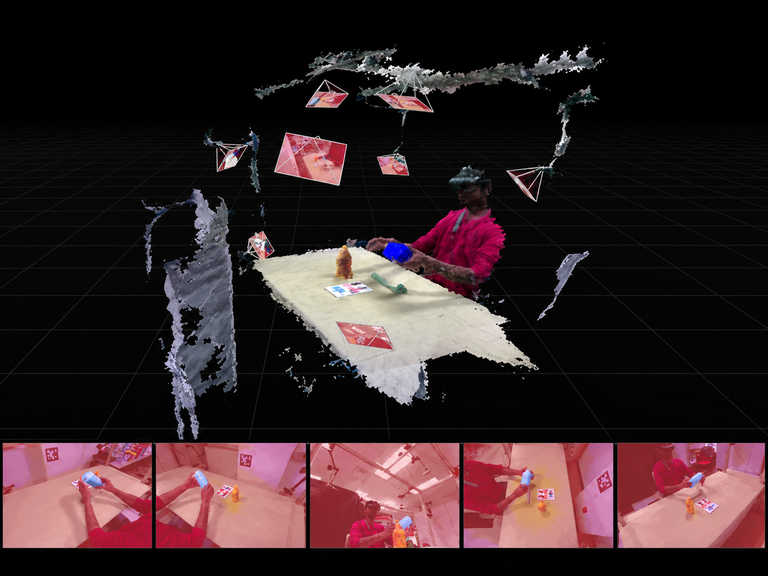
Prepare
Interactive 3D annotation app with Rerun and Gradio
Interactive 3D annotation app built with Gradio and SAM 2. Track objects in monocular video, or fuse masks across multi-view RGB-D.
2D 3D Pinhole camera Time series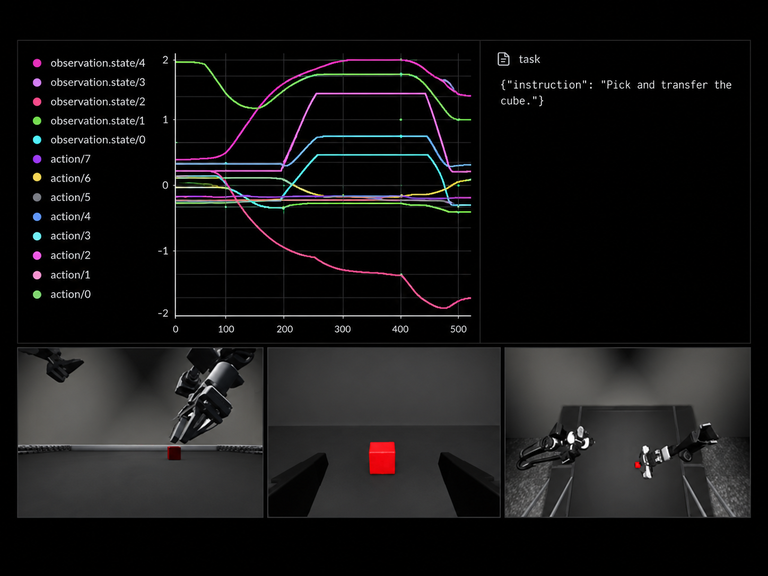
Prepare → Train
LeRobot dataset from RRD
Convert RRD robot recordings into LeRobot v3 training datasets using the OSS Rerun server, with video remuxing.
Robotics MCAP LeRobot Dataset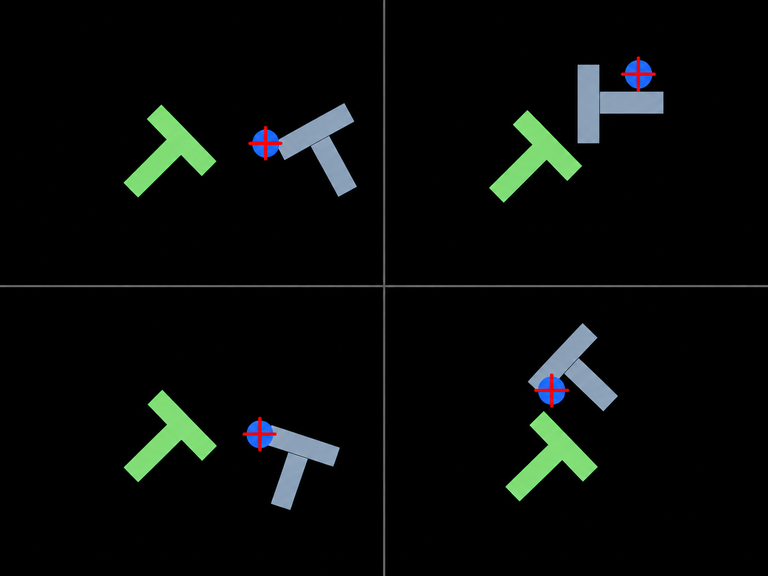
Train
Training a model on the LeRobot dataset
Train a LeRobot policy on Hugging Face's `pusht` dataset and watch the training progress live in Rerun.
2D Hugging Face Imitation learning
Ready to log your own data?
Install the SDK in one line, log a few things, and open the viewer.